TECHNICAL PROPOSAL SPECIFICATIONS
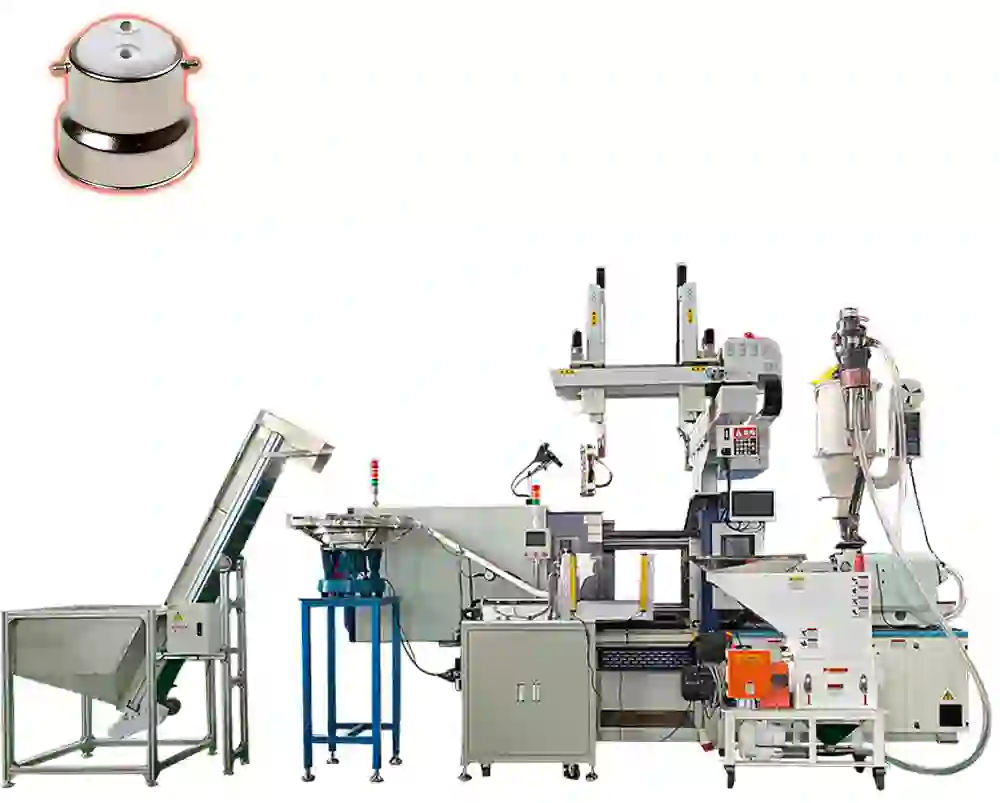
Injection cell
configuration.
Figures shown are technical proposal values for the B22 project.
DOCUMENTED PROCESS
Feeding to
runner recovery.
- 01Vibratory feeding
- 02Automatic arrangement
- 03Robot mold loading
- 04Injection molding
- 05Part and runner unloading
- 06Runner crushing
ENGINEERING CONFIGURATION
ROBOT HANDLING
Five-axis servo robot
- Maximum load
- 15 kg
- Vertical stroke
- 900 mm
- Pull-out stroke
- 600 mm
- Traverse travel
- 1,540 mm
- Empty cycle
- 8.8 s
MOLD AND MATERIAL
48-cavity cold-runner mold
- Mold frame
- No. 50 steel
- Mold core
- S136
- Feed point
- Single feed point
- Specified materials
- PBT, PC and other materials
- Runner handling
- JY-3HP crusher listed in the proposal
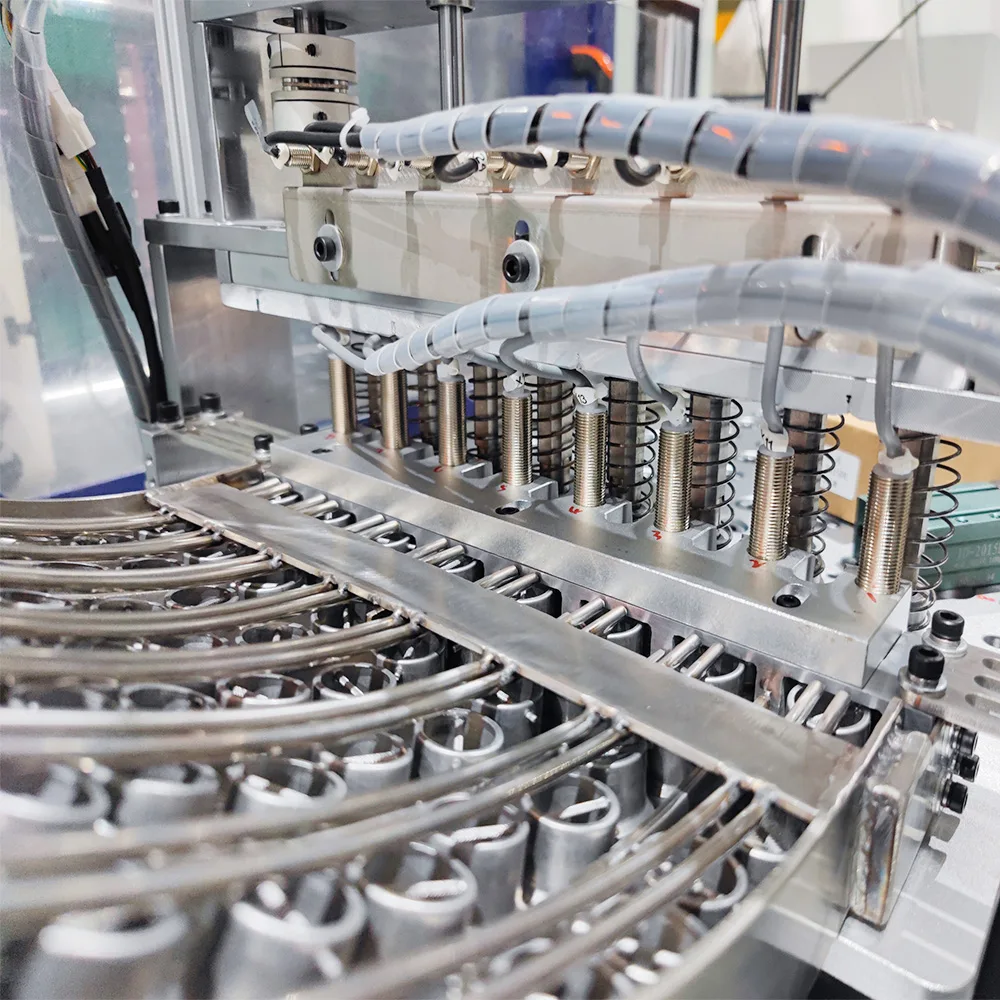
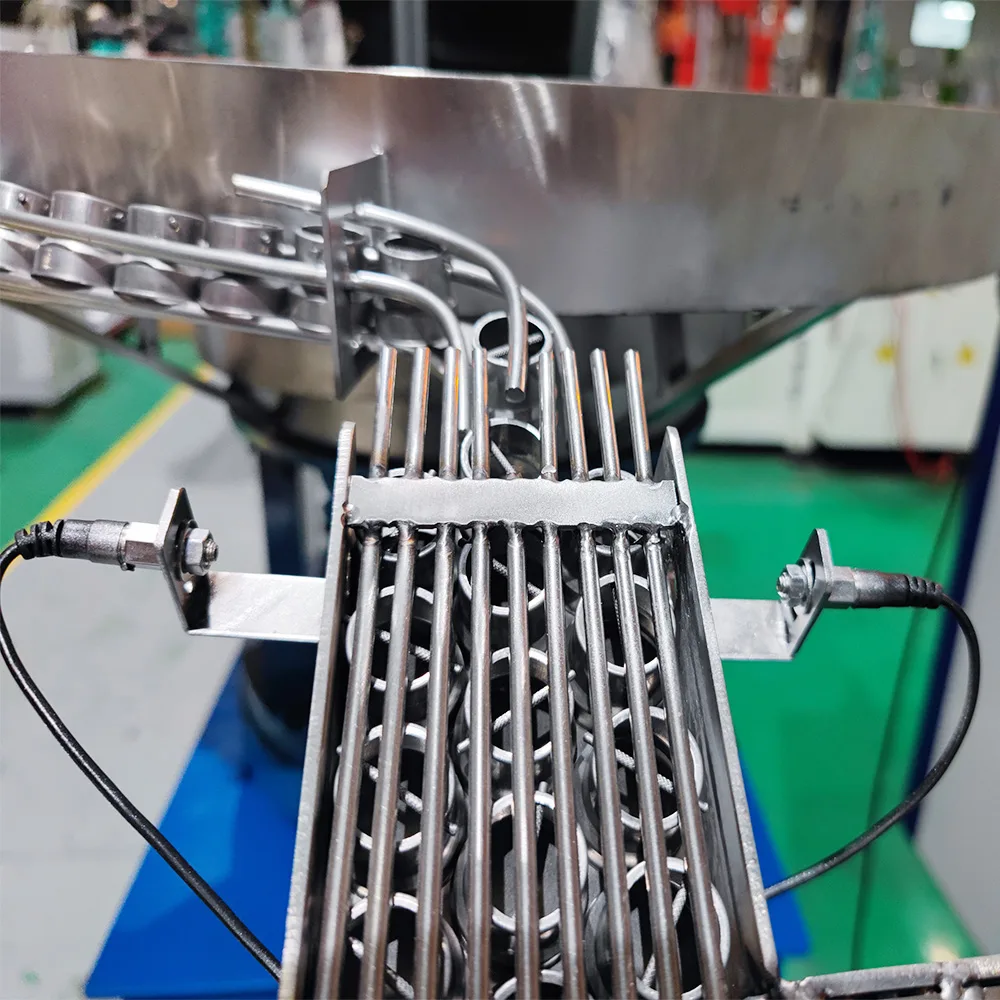
EQUIPMENT AND TOOLING
START A PROJECT
Tell us what you need
to manufacture.
Share your product, process and automation goal.
Request assessment